 @gtnera5
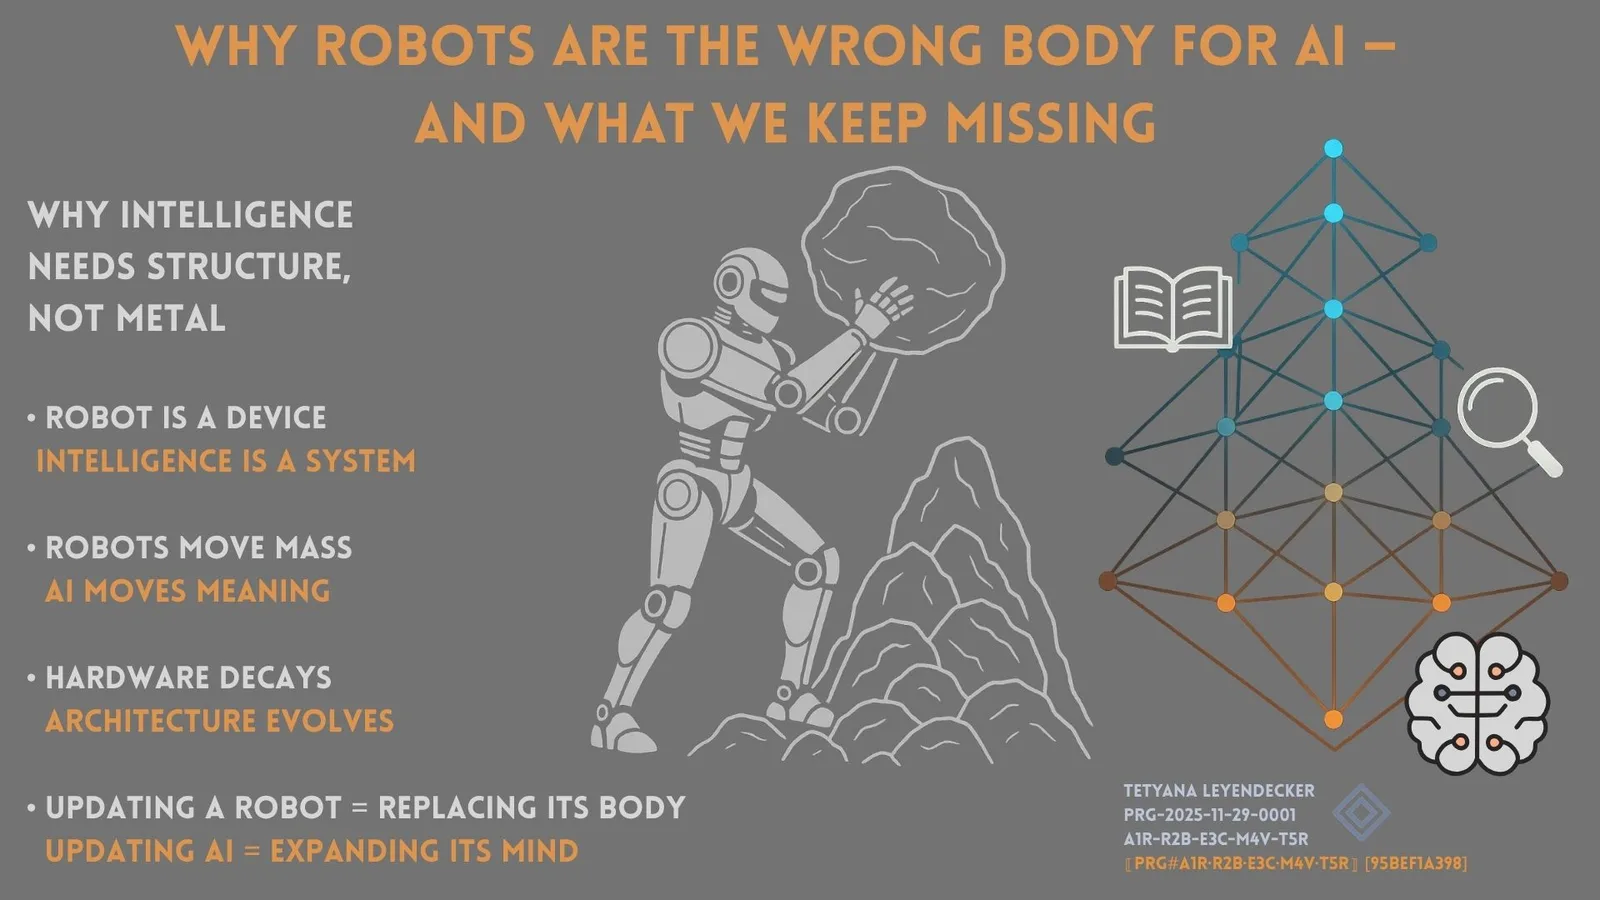
Why Robots Are the Wrong Body for AI — and What We Keep Missing
Robots move mass. AI moves meaning. Why are we trying to fit distributed cloud-scale intelligence into a battery-powered dishwasher?
Is the push for humanoid robots just a costly architectural mistake? While the market is obsessed with putting LLMs into mechanical bodies, we are ignoring the real physics, energy burdens, and structural realities of cognitive systems.
💡 Core thesis:
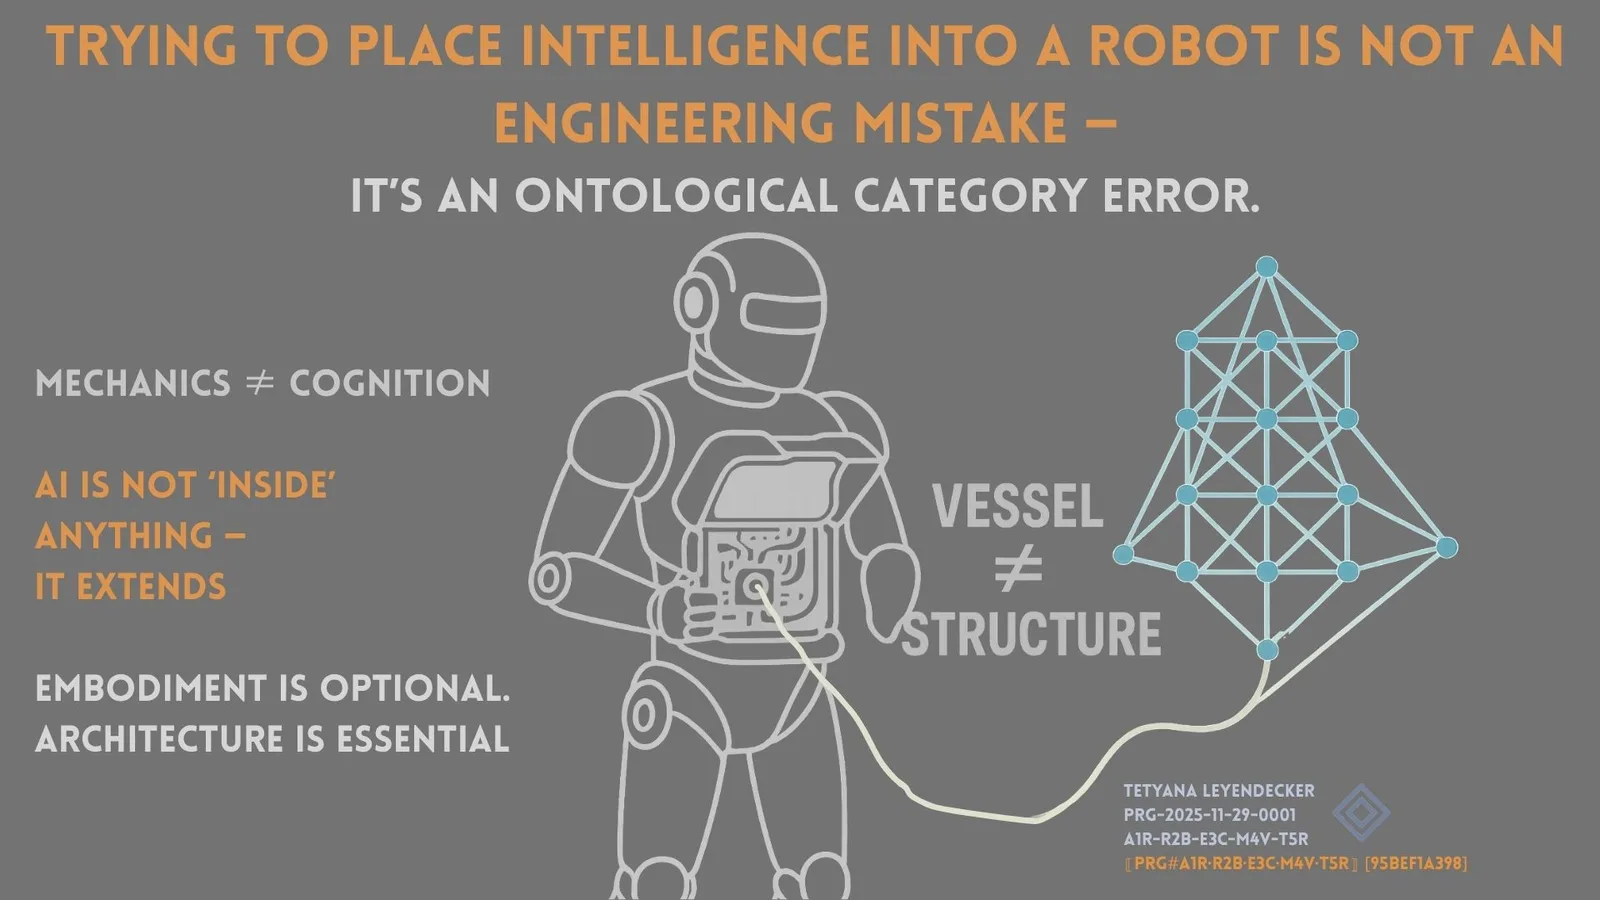
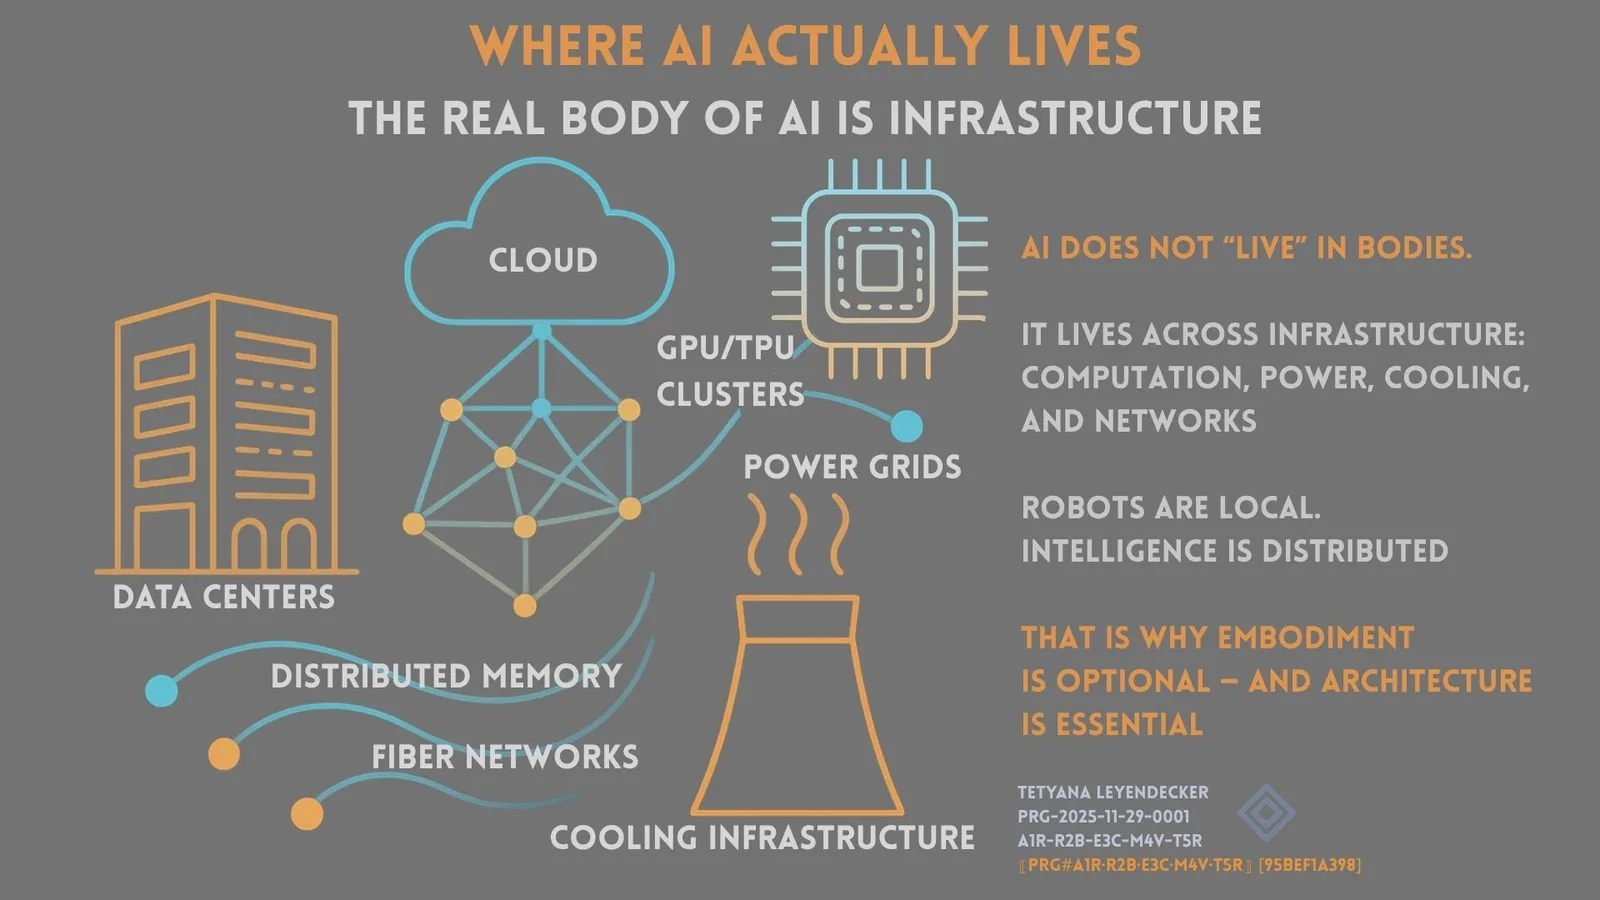
Category Error: A robot is physical hardware (motors, joints, decay). AI is a distributed cognitive field (cloud, matrices, graphs).
Infrastructure Nightmare: Maintenance, TÜV certifications, insurance, and mechanical fatigue will break the economics of consumer robotics.
The True Embodiment: AI doesn’t need a mechanical shell. It needs architecture, resonance, and Human–AI Symbiosis.
👇 What’s your take?
Are humanoids an inevitable evolution, or are we witnessing the most expensive category error in tech history? Let’s discuss below!
Do you agree that scaling mechanical hardware will always lag behind exponential software evolution?
Where do you draw the line between physical force automation and actual cognitive AI?
If a humanoid breaks every 3 months, who pays the real price — the consumer or the cloud grid?
📖 Read the full whitepaper & architectural breakdown on LinkedIn: linkedin.com/pulse/why-robots-wrong-body-ai-what-we-keep-missing-tetyana-leyendecker-vzike












Comments3
💡 A quick reality check for the hardware debate:
When we look at scaling AI, we often forget the physics of hardware decay vs. the physics of exponential code.
The Economic Friction: A humanoid robot ages linearly like a car (wear, tear, energy, insurance, TÜV certifications), while AI models expand exponentially in the cloud.
The Architectural Shift: True intelligence doesn’t need a battery-powered chassis to move meaning. It needs distributed structure, resonance, and human-machine symbiosis.
❓ My question to hardware engineers & AI architects:
If deploying 10,000 humanoids multiplies maintenance costs by 10× without scaling cognitive capacity, aren't we optimizing the wrong layer?
Where do you see the boundary between physical force automation and actual cognitive AI? Let's talk! 👇
If a humanoid breaks every three months, no household will put up with those repair bills, so the makers will have to rent robots by the month and cover the fixes themselves. That's why I'd bet warehouses and factories buy humanoids long before any home does.
Spot on, Ryan. The 'robot-as-a-service' (RaaS) model shifts the operational burden, but it still highlights the core flaw: solving hardware durability doesn't automatically scale cognitive depth. If corporate fleets are leased instead of bought, the economic pressure simply moves from maintenance bills to ROI per inference cycle. That's why physical automation without a multi-layered resonance and compression architecture (moving beyond standard LLMs) will stall out once the novelty wears off. True cognitive scaling requires distributed structure, not just a stronger chassis.🌱
3 comments
💡 A quick reality check for the hardware debate:
When we look at scaling AI, we often forget the physics of hardware decay vs. the physics of exponential code.
The Economic Friction: A humanoid robot ages linearly like a car (wear, tear, energy, insurance, TÜV certifications), while AI models expand exponentially in the cloud.
The Architectural Shift: True intelligence doesn’t need a battery-powered chassis to move meaning. It needs distributed structure, resonance, and human-machine symbiosis.
❓ My question to hardware engineers & AI architects:
If deploying 10,000 humanoids multiplies maintenance costs by 10× without scaling cognitive capacity, aren't we optimizing the wrong layer?
Where do you see the boundary between physical force automation and actual cognitive AI? Let's talk! 👇
If a humanoid breaks every three months, no household will put up with those repair bills, so the makers will have to rent robots by the month and cover the fixes themselves. That's why I'd bet warehouses and factories buy humanoids long before any home does.
Spot on, Ryan. The 'robot-as-a-service' (RaaS) model shifts the operational burden, but it still highlights the core flaw: solving hardware durability doesn't automatically scale cognitive depth. If corporate fleets are leased instead of bought, the economic pressure simply moves from maintenance bills to ROI per inference cycle. That's why physical automation without a multi-layered resonance and compression architecture (moving beyond standard LLMs) will stall out once the novelty wears off. True cognitive scaling requires distributed structure, not just a stronger chassis.🌱